Lessons
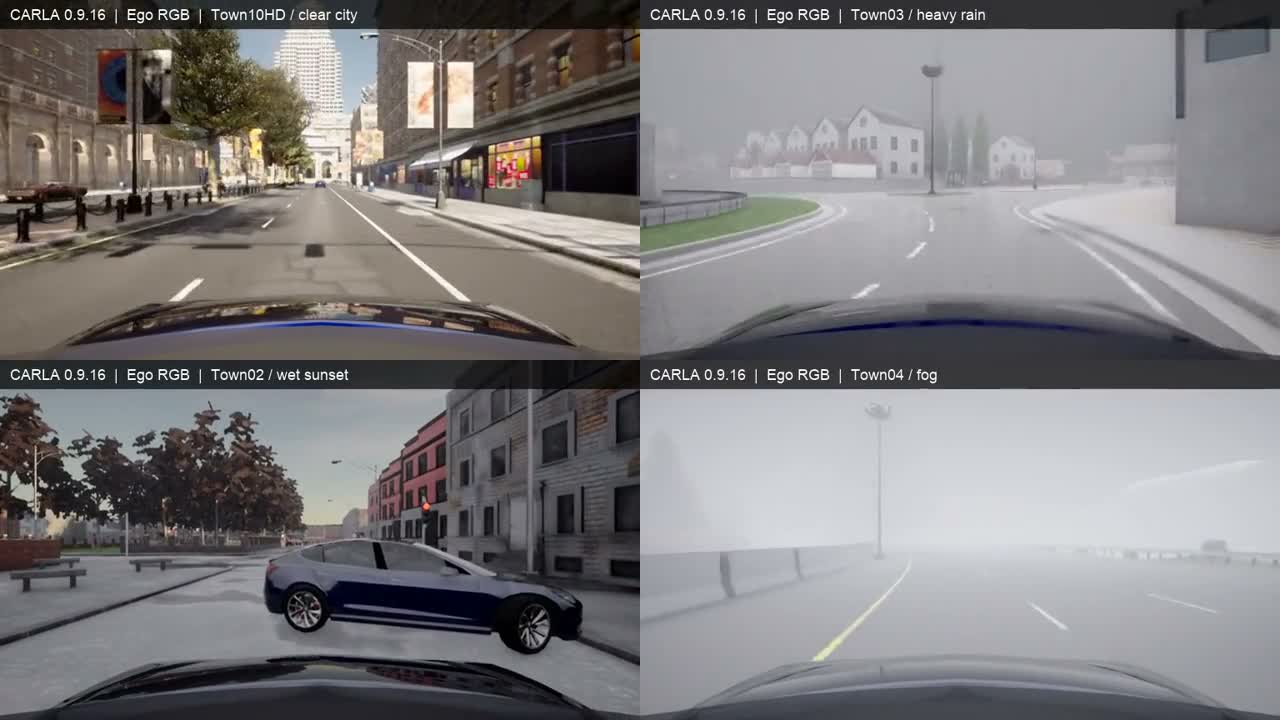
- See through the ego cameraWatch four recorded CARLA environments, then follow setup and record your own sensors.GPU lab
- Read a learned model’s outputInspect six-camera inputs and Alpamayo’s future poses; distinguish inference from a driving rollout.GPU lab
- Prepare a NuRec sceneCheck access, the example scene ID, and the pinned AlpaSim revision.Guided example
- Run one baseline rolloutFollow the official setup and launch the baseline on a single scene.Guided example
- Inspect the result and set up a comparisonFind the metrics and hold the scene and renderer fixed before changing the policy.Guided example