Recorded run
Generate and explore a world from text or an image
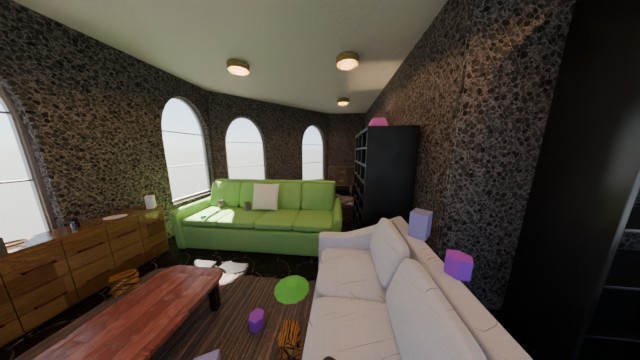
WorldGen creates a robotics lab, a forest trail and an expanded living room. Watch translated 3D camera views, then load the generated scene in your browser.
Explore 3D Gaussian scenes, generate indoor geometry, and compare these with neural 3D world generation and video world models.
Recorded run
WorldGen creates a robotics lab, a forest trail and an expanded living room. Watch translated 3D camera views, then load the generated scene in your browser.
Recorded run
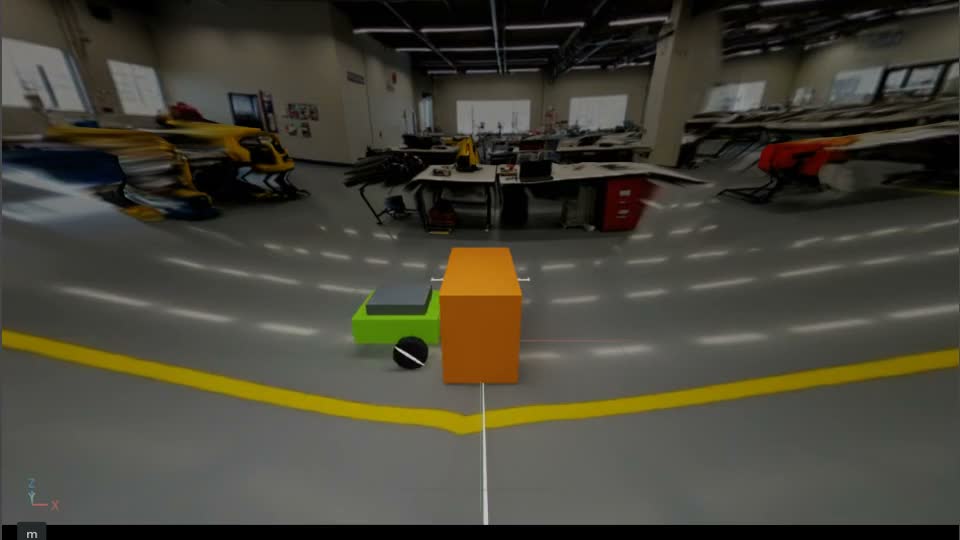
A generated laboratory becomes an Isaac Sim 6.2 scene. Watch an articulated AMR meet a crate, reverse and follow waypoints around it. The recovery is scripted; contacts and motion are live PhysX.
Recorded run
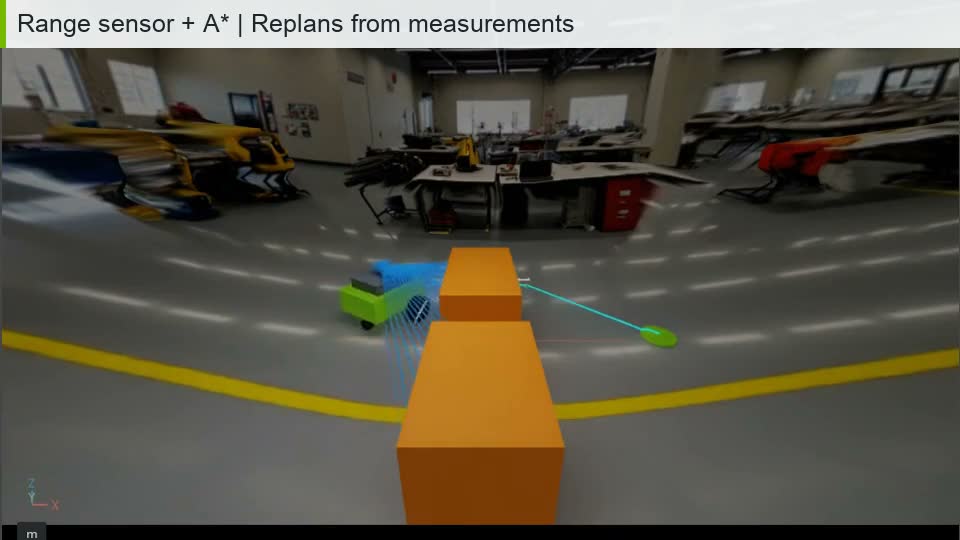
A new box blocks the old route. An actual Physics Raycast Sensor feeds an occupancy grid and A* planner, and the same robot chooses the other side. Native Isaac Sim GUI footage at 1× speed.
Recorded run
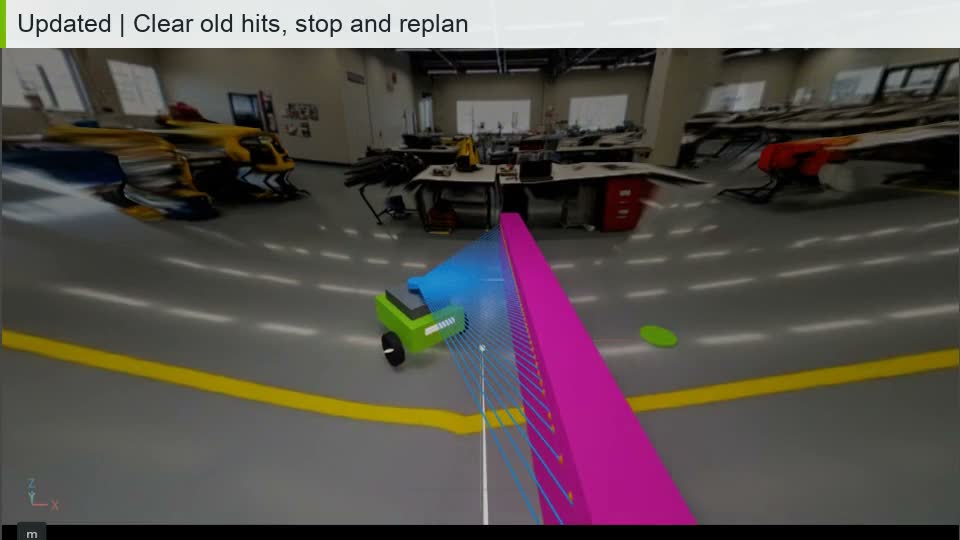
A gate closes during driving and reopens. The old permanent map still blocks the robot; fresh range observations let the new controller wait, clear the map and continue. Actual Isaac Sim GUI recordings at 1×.
Recorded run
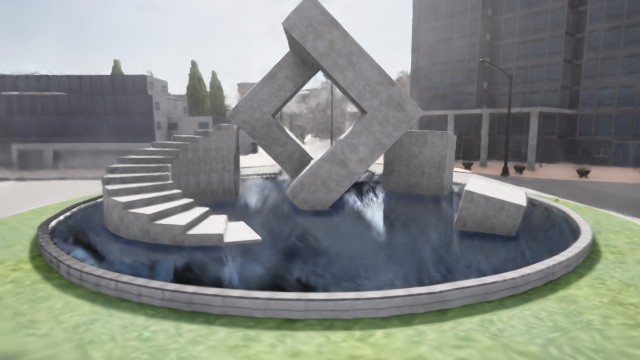
CARLA camera views become an fVDB radiance field. Move the viewpoint in the browser, or watch the full model rendered along a new camera path.
Recorded run
Infinigen generates a furnished house and plans a camera tour. Blender Cycles renders the geometry; this is procedural generation, not neural world-model inference.
Recorded run
A real Cosmos camera-conditioned generation, then an Alpamayo prediction replay in Isaac Sim. Separate model experiments on our own scenes.
Reference guide
See how video and scene conditions become inputs for generation or reasoning.
Reference guide
Follow a request from a video analysis app to a model endpoint and see what to check before serving it.