Recorded run
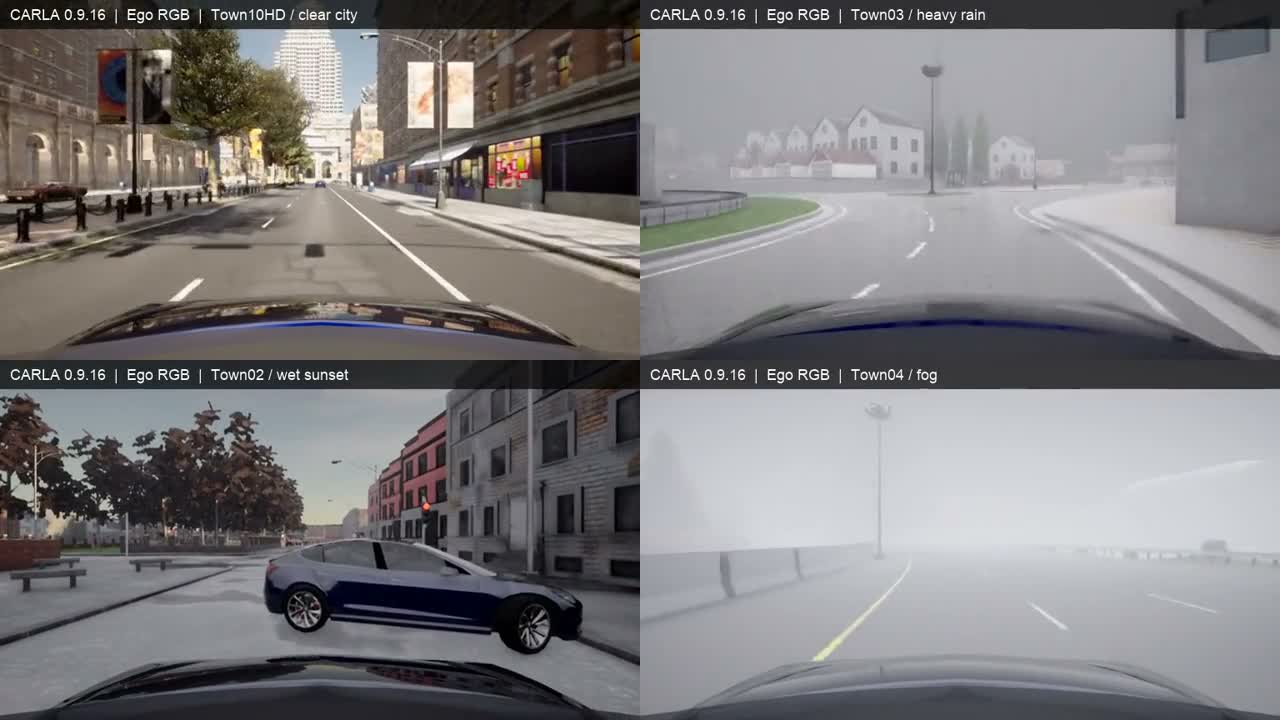
Four environments from the driver’s seat
Actual CARLA ego cameras: clear city, heavy rain, wet sunset, and fog. Traffic Manager is a rule-based driver; these are sensor captures, not AI policy results.
Start in the driver’s seat across four CARLA maps and weather conditions, then distinguish sensor simulation, learned trajectory inference and closed-loop evaluation.
View pathRecorded run
Actual CARLA ego cameras: clear city, heavy rain, wet sunset, and fog. Traffic Manager is a rule-based driver; these are sensor captures, not AI policy results.
Reference guide
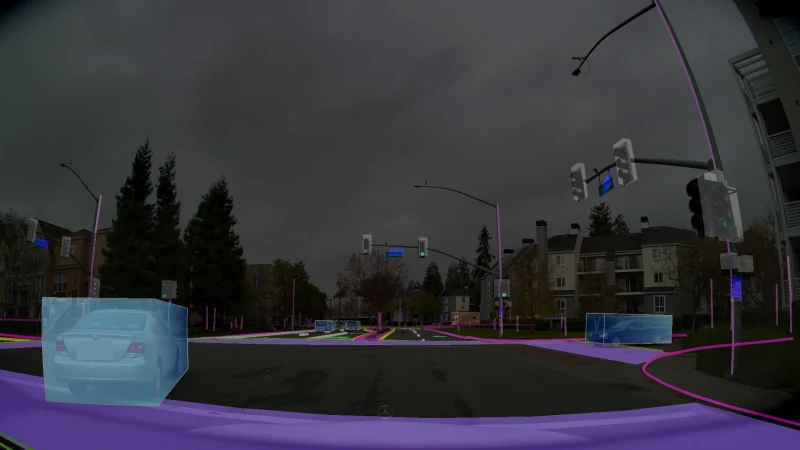
Run the baseline policy on one reconstructed driving scene with the NuRec renderer.
Recorded run
A real Cosmos camera-conditioned generation, then an Alpamayo prediction replay in Isaac Sim. Separate model experiments on our own scenes.