Recorded run
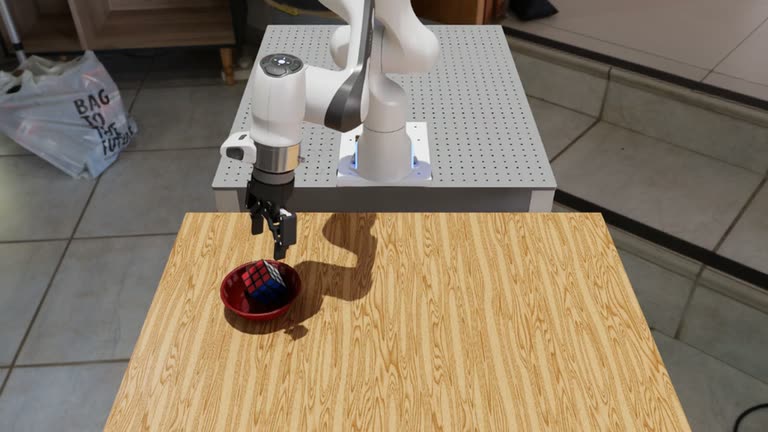
GR00T puts the cube in the bowl
Watch the gripper hold, carry, open, and leave the cube resting in the bowl.
See what each stack can do, then open the lab for the commands, scene files, and checks.
Recorded run
Watch the gripper hold, carry, open, and leave the cube resting in the bowl.
Recorded run
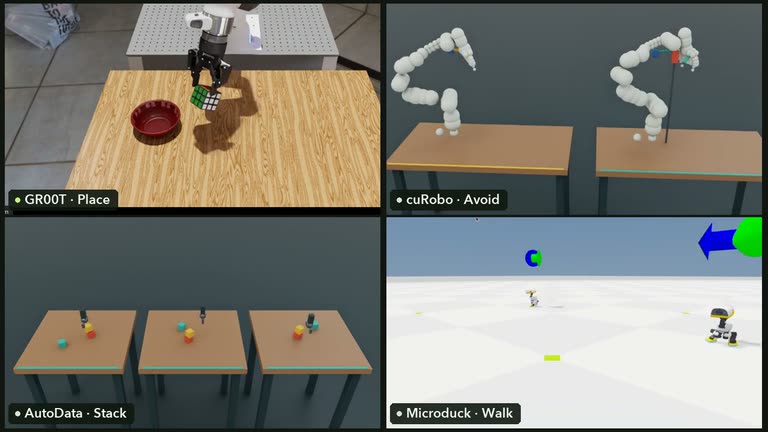
GR00T places the cube, cuRobo plans around an obstacle, AutoData replays generated demonstrations, and a trained Microduck policy walks in Newton.
Recorded run
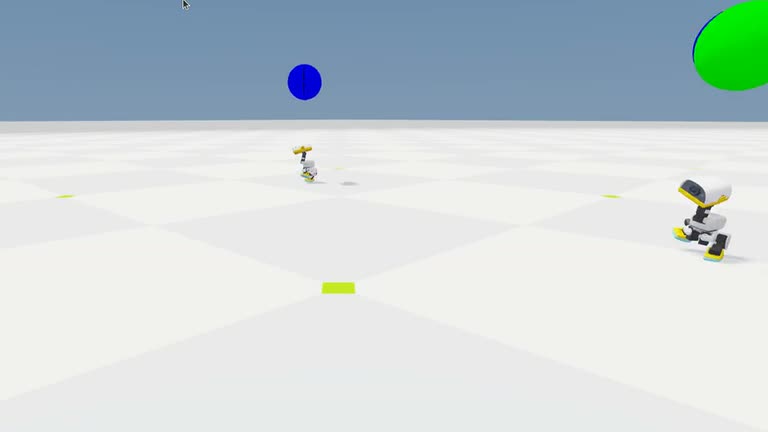
A walking policy trained in Isaac Lab drives the simulated robot.
Recorded run
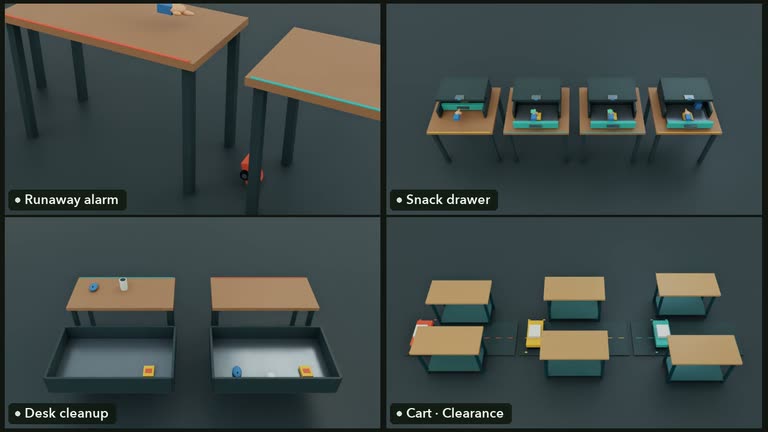
An alarm rolls away, a snack drawer responds to a card, a cleanup rule puts a mouse in the bin, and a cart tests aisle widths.
Recorded run
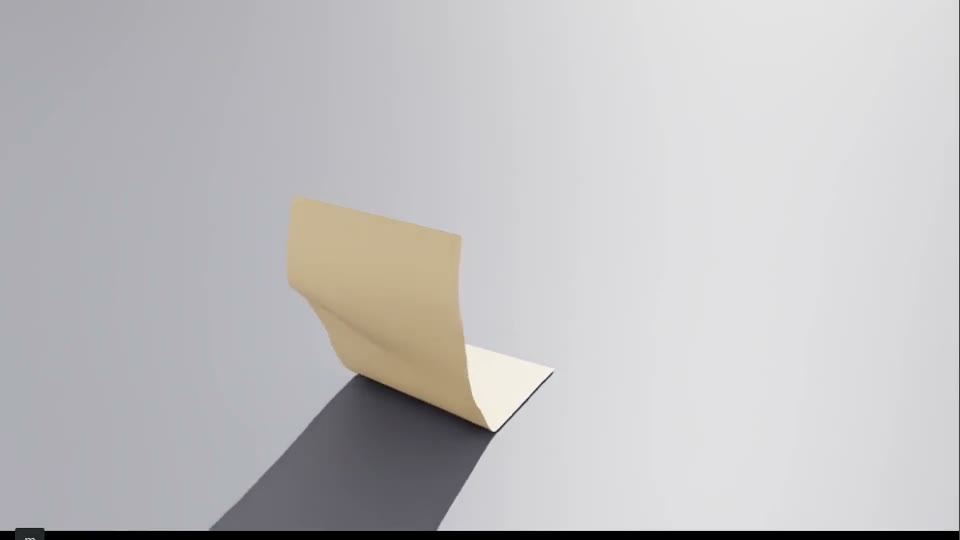
Newton computes XPBD cloth, VBD cloth, and twisting cables. Isaac Sim displays the saved solver states.
Recorded run
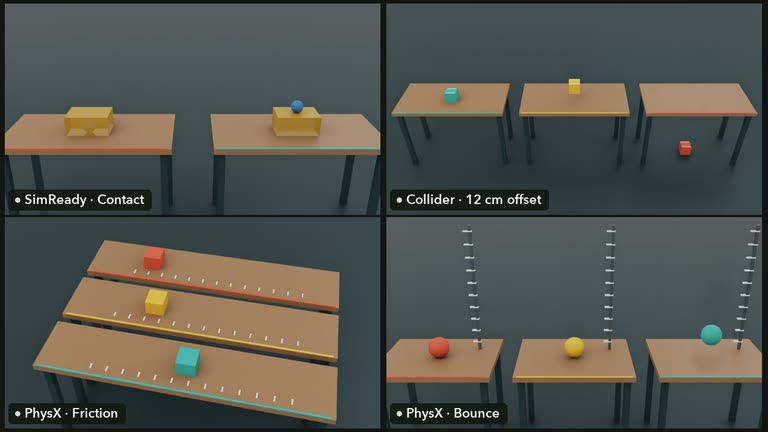
Colliders change where objects stop. Friction changes how far they slide, and restitution changes how high they bounce.
Recorded run
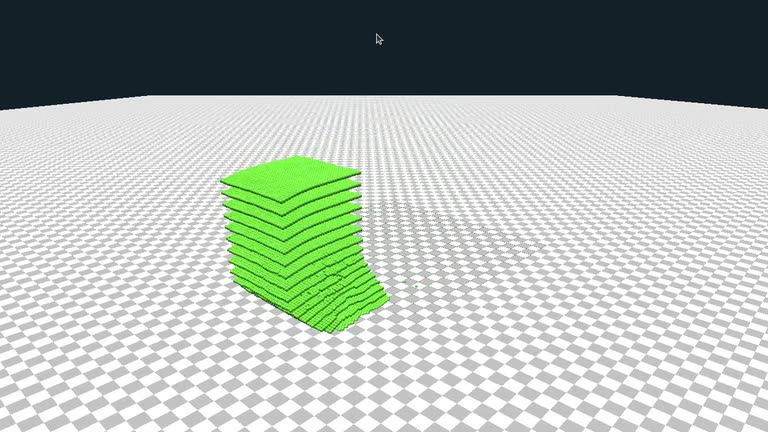
Warp computes 65,536 interacting particles on the GPU. The viewer draws one in four.
Recorded run
WorldGen creates a robotics lab, a forest trail and an expanded living room. Watch translated 3D camera views, then load the generated scene in your browser.
Recorded run
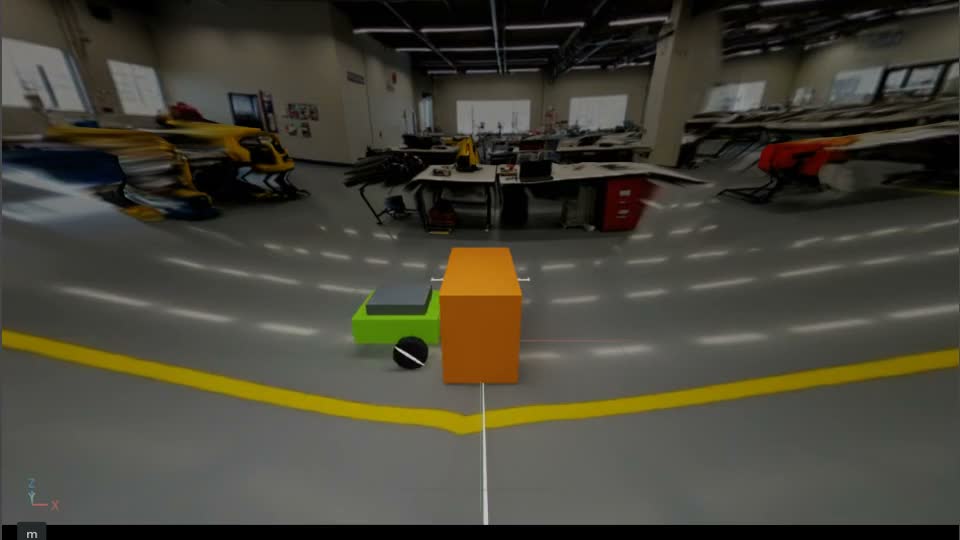
A generated laboratory becomes an Isaac Sim 6.2 scene. Watch an articulated AMR meet a crate, reverse and follow waypoints around it. The recovery is scripted; contacts and motion are live PhysX.
Recorded run
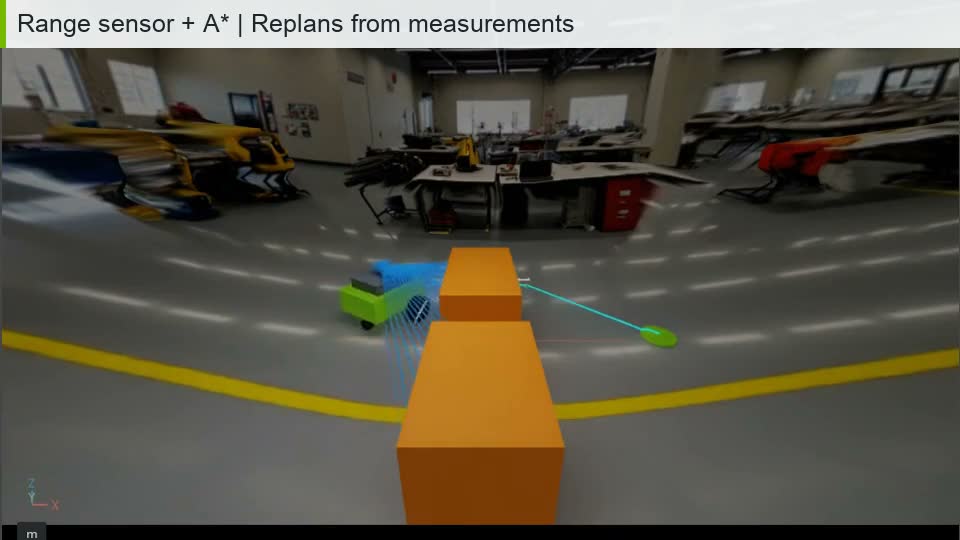
A new box blocks the old route. An actual Physics Raycast Sensor feeds an occupancy grid and A* planner, and the same robot chooses the other side. Native Isaac Sim GUI footage at 1× speed.
Recorded run
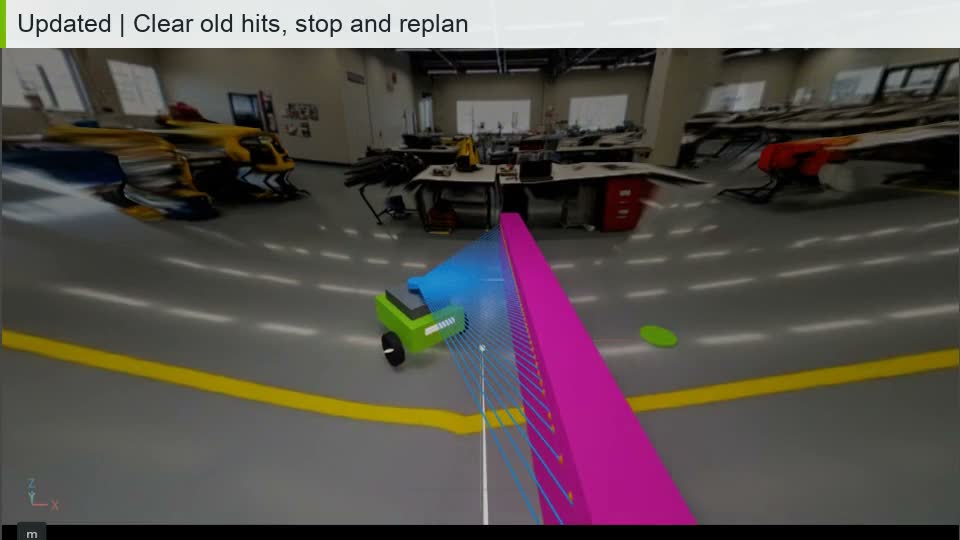
A gate closes during driving and reopens. The old permanent map still blocks the robot; fresh range observations let the new controller wait, clear the map and continue. Actual Isaac Sim GUI recordings at 1×.
Recorded run
CARLA camera views become an fVDB radiance field. Move the viewpoint in the browser, or watch the full model rendered along a new camera path.
Recorded run
Infinigen generates a furnished house and plans a camera tour. Blender Cycles renders the geometry; this is procedural generation, not neural world-model inference.
Recorded run
A real Cosmos camera-conditioned generation, then an Alpamayo prediction replay in Isaac Sim. Separate model experiments on our own scenes.
Reference guide
See how video and scene conditions become inputs for generation or reasoning.
Reference guide
Follow a request from a video analysis app to a model endpoint and see what to check before serving it.
Recorded run
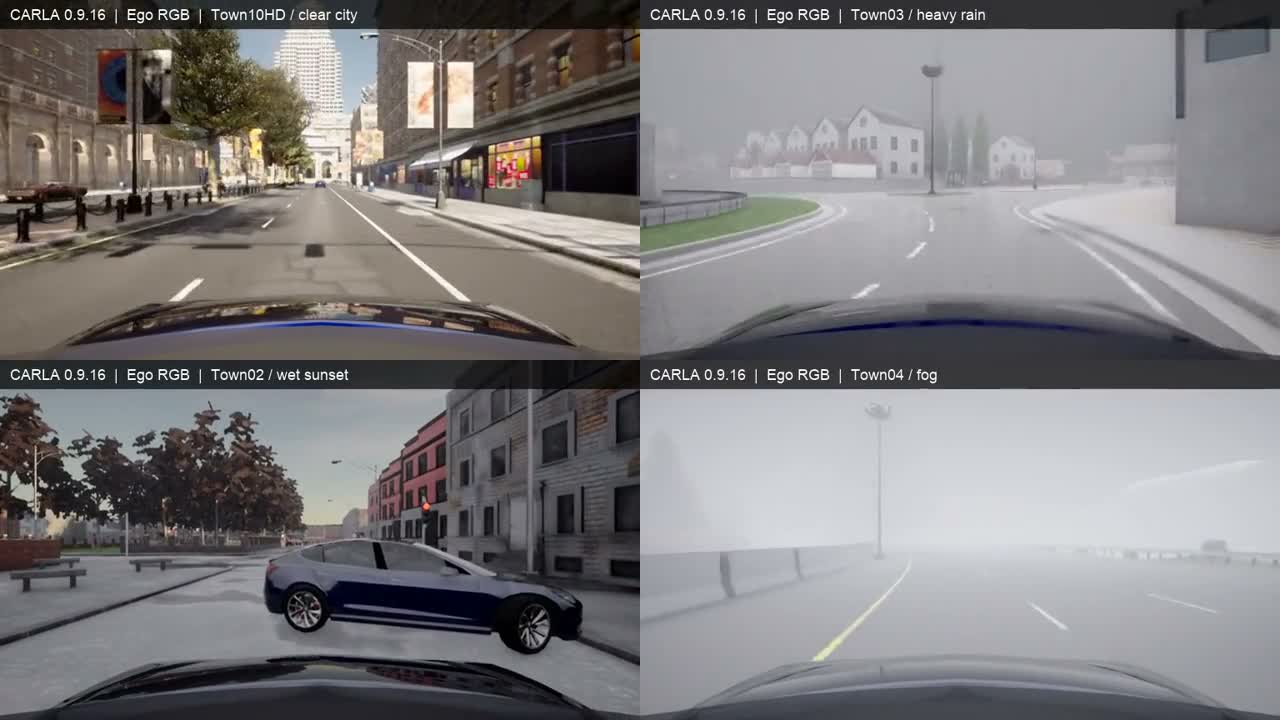
Actual CARLA ego cameras: clear city, heavy rain, wet sunset, and fog. Traffic Manager is a rule-based driver; these are sensor captures, not AI policy results.
Reference guide
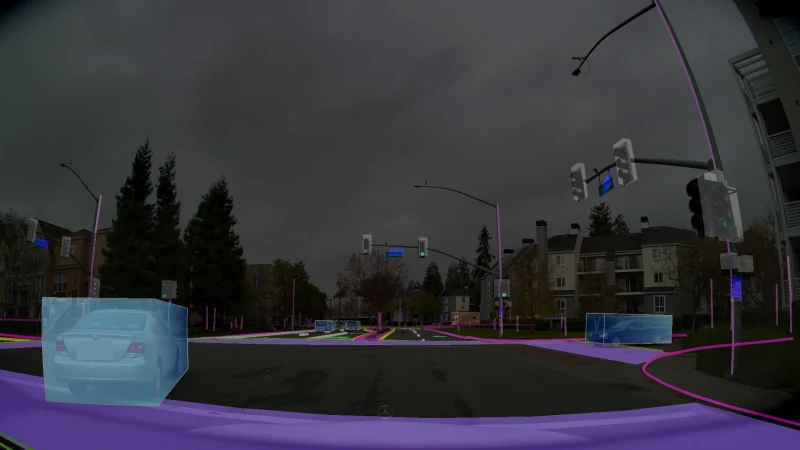
Run the baseline policy on one reconstructed driving scene with the NuRec renderer.
Recorded run
A real Cosmos camera-conditioned generation, then an Alpamayo prediction replay in Isaac Sim. Separate model experiments on our own scenes.
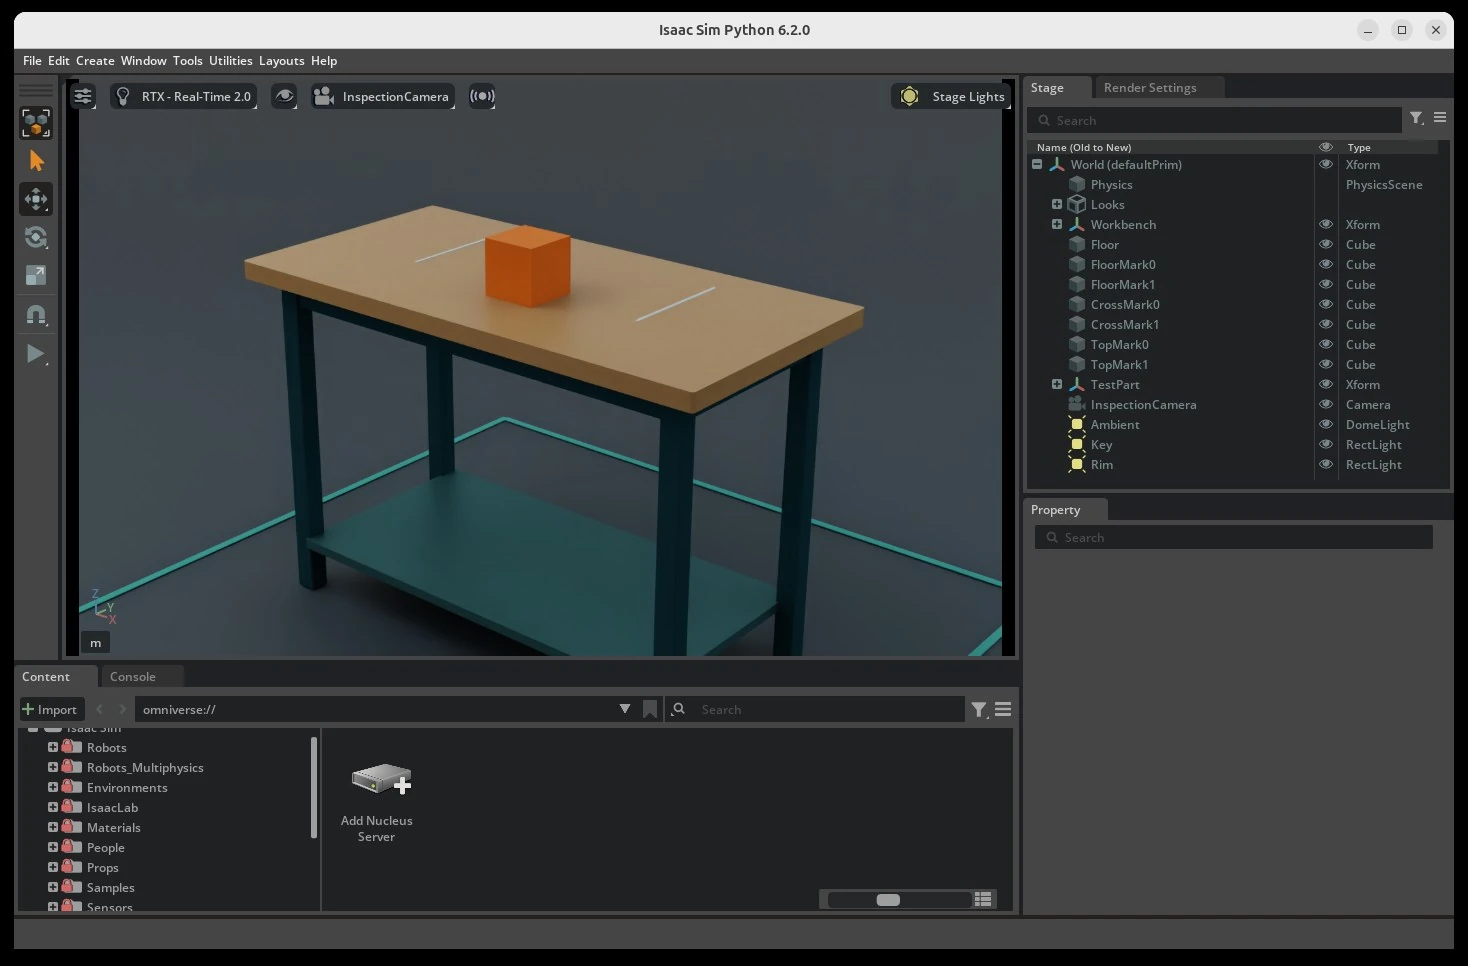
Lab capture
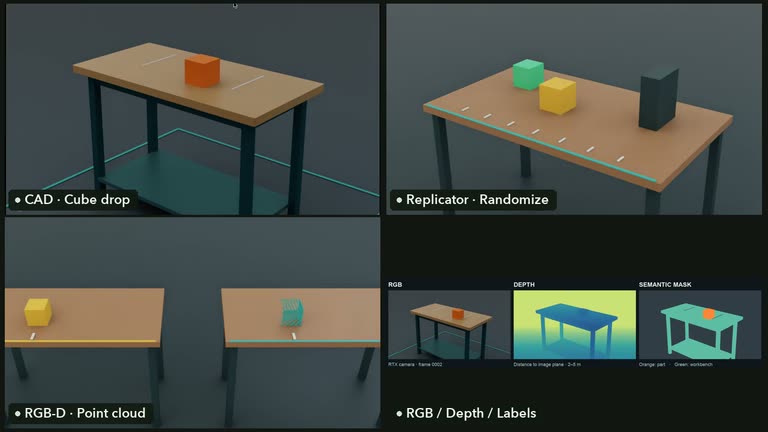
Turn CAD into an Isaac Sim scene, capture RGB, depth and masks, then check the result on a CPU.
Recorded run
Open a CAD workbench, vary the camera scene in Replicator, and inspect RGB, depth, labels, and a reconstructed point cloud.
Advanced lab
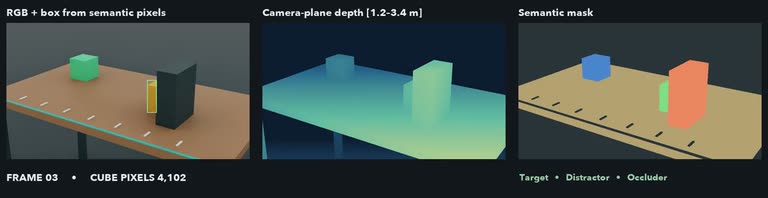
Inspect RGB, camera-plane depth, and semantic masks from 12 captured frames.