Recorded run
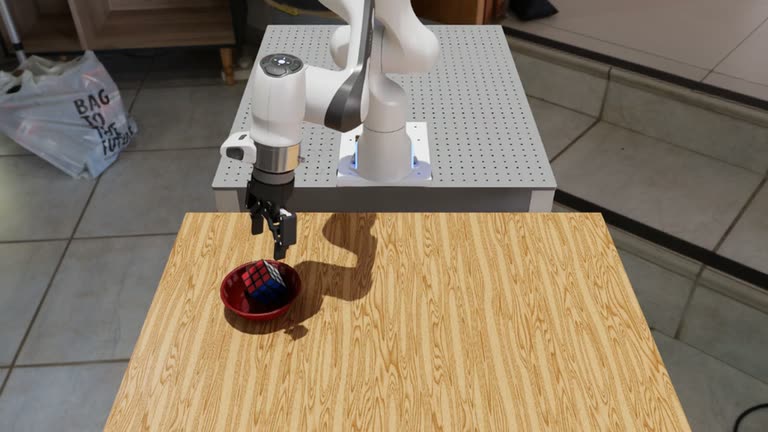
GR00T puts the cube in the bowl
Watch the gripper hold, carry, open, and leave the cube resting in the bowl.
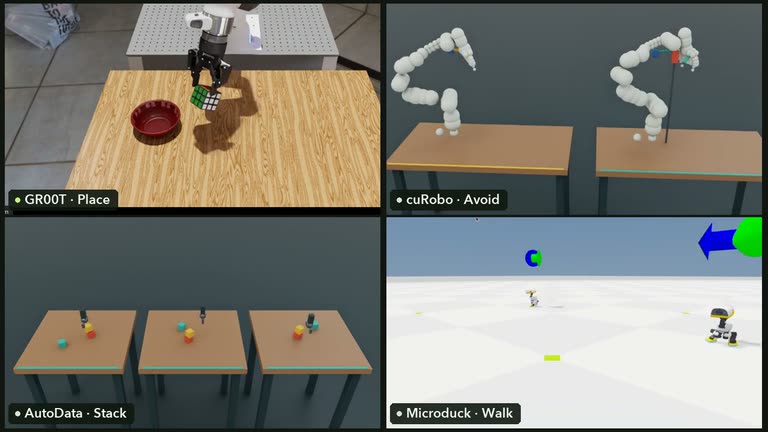
Check a pick-and-place policy, plan around obstacles, and replay a learned walk.
View pathRecorded run
Watch the gripper hold, carry, open, and leave the cube resting in the bowl.
Recorded run
GR00T places the cube, cuRobo plans around an obstacle, AutoData replays generated demonstrations, and a trained Microduck policy walks in Newton.
Recorded run
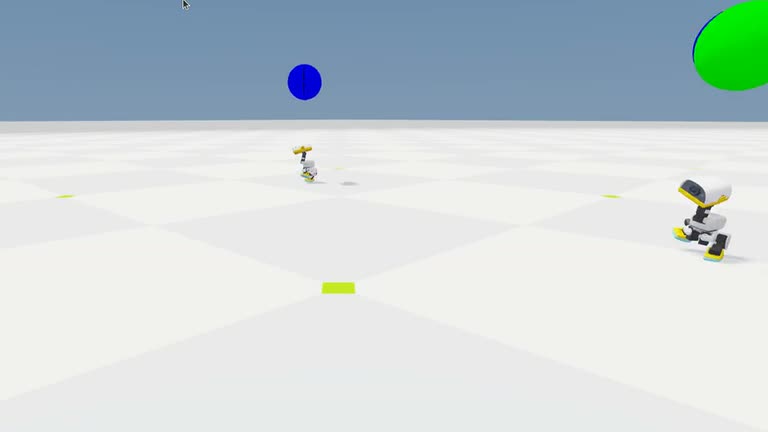
A walking policy trained in Isaac Lab drives the simulated robot.
Recorded run
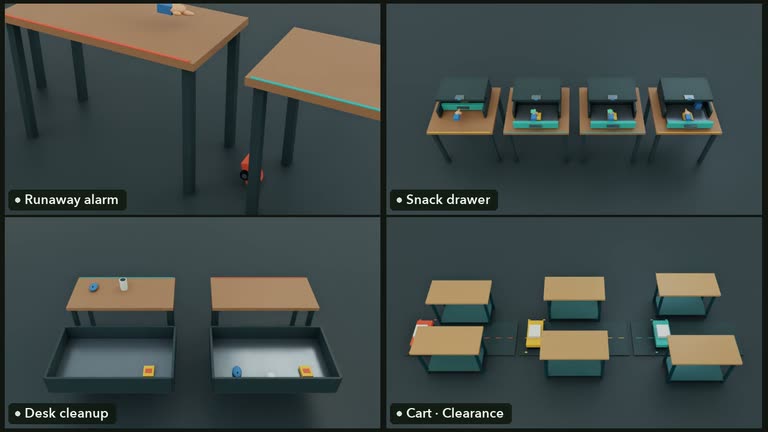
An alarm rolls away, a snack drawer responds to a card, a cleanup rule puts a mouse in the bin, and a cart tests aisle widths.